About Me
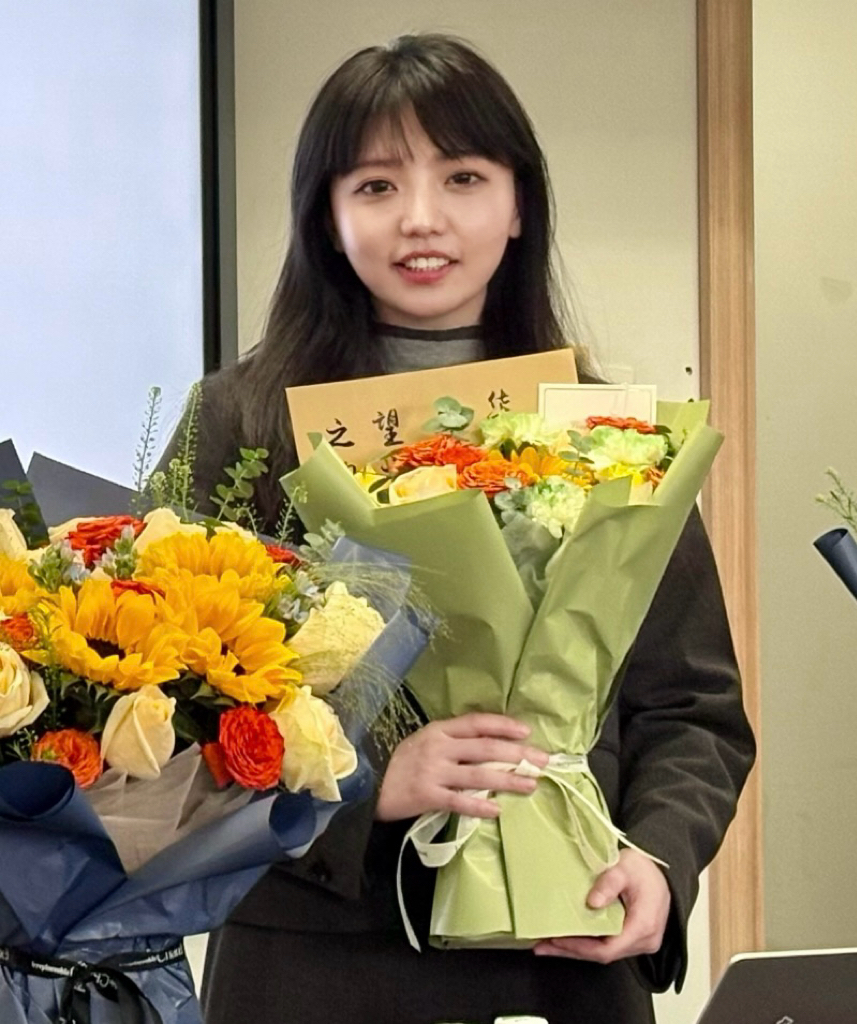
Hi! I am Zixuan Chen (陈子璇). I received my Ph.D. degree from the School of Computer Science and Technology, Nanjing University (NJU) in March 2026, advised by Prof. Yang Gao and Assoc. Prof. Jing Huo. I have joined the School of Intelligent Science and Technology, Nanjing University (Suzhou Campus) as a Postdoctoral Researcher (Yuxiu Young Scholar).
Previously, I received my B.E. and M.E. degrees from Soochow University, School of Computer Science and Technology, under the supervision of Prof. Zongzhang Zhang. From Nov. 2024 to Nov. 2025, I was a visiting student at the National University of Singapore (NUS), working with Prof. Lin Shao.
Research Interests
My research focuses on Robot Learning, Reinforcement Learning, and Imitation Learning for embodied agents. I am particularly interested in three complementary directions, one target problem supported by two core capabilities:
- Long-horizon Embodied Tasks: Leveraging prior knowledge from vision-language models (VLMs) to build agentic frameworks for task decomposition, skill composition, and closed-loop execution in long-horizon manipulation, contact-rich dexterous manipulation, mobile manipulation, and humanoid loco-manipulation.
- Spatial Intelligence: Grounding actions in the physical world through generalizable 3D spatial perception and reasoning (e.g., geometric relations, affordances).
- Embodied World Models: Learning generative models of environment dynamics to enable predictive planning and scalable data generation.
News
- 2026.09 Selected for the 2026 Jiangsu Young Science and Technology Talent Support Program.
入选2026年江苏省青年科技人才托举工程。 - 2026.09 Received the 2026 CCF Ph.D. Dissertation Incentive Award (recommended by the Technical Committee on Intelligent Robotics).
获2026年度CCF博士学位论文激励计划(智能机器人专委会推荐)。 - 2026.07 Recognized as a Yuxiu Young Scholar at Nanjing University.
- 2026.07 Preprint "Wh0" (Generative World Models as Scalable Sources of Egocentric Human Hand Manipulation Data) was released.
- 2026.06 "INHerit-SG" was selected as a Best Presentation Finalist at the ICRA 2026 Workshop on Robots Meet Prior Maps.
- 2026.06 "RoboHorizon" was accepted to SCIENCE CHINA Information Sciences (SCIS).
- 2026.06 "V-Dreamer" received the Best Paper Award at the ICRA 2026 Workshop on Generative Digital Twins for Real2Sim and Sim2Real Transfer.
- 2026.04 Invited talk at Zhuoyu Technology (卓驭科技), Shenzhen, China.
- 2026.02 "AGiLe" was accepted to CVPR 2026.
- 2026.01 4 papers (RoTri-Diff, LaViRA, AdaptPNP and LISN) were accepted to ICRA 2026.
- 2026.01 "DeCo" was accepted to RAL 2026.
- 2025.11 "ManiLong-Shot" was accepted to AAAI 2026.
- 2025.10 Preprint "RoboHiMan" (Compositional Generalization in Long-horizon Manipulation) was released.
- 2025.05 Preprint "DeCo" (Task Decomposition and Skill Composition for Long-horizon Manipulation) was released.
- 2025.01 "GravMAD" was accepted to ICLR 2025.
- 2025.01 Preprint "RoboHorizon" (World Model for Long-horizon Manipulation) was released.
- 2024.09 "SCaR" (Skill Chaining) was accepted to NeurIPS 2024.
- 2023.12 "Cognizing and Imitating Robotic Skills" was accepted to AAMAS 2024.
- 2023.01 "TiLD" was accepted to AAMAS 2023.
Selected Publications
(* equal contribution)
2026
-
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026.
-
IEEE International Conference on Robotics and Automation (ICRA), 2026.
-
IEEE Robotics and Automation Letters (RAL), 2026.
-
AAAI Conference on Artificial Intelligence (AAAI), 2026.
-
SCIENCE CHINA Information Sciences (SCIS), 2026.
-
arXiv preprint arXiv:2602.12971, 2026. (Best Presentation Finalist, ICRA 2026 Workshop on Robots Meet Prior Maps)
-
arXiv preprint arXiv:2606.22136, 2026.
-
arXiv preprint arXiv:2603.10616, 2026.
-
arXiv preprint arXiv:2603.18811, 2026. (Best Paper Award, ICRA 2026 Workshop on Generative Digital Twins for Real2Sim and Sim2Real Transfer)
-
arXiv preprint arXiv:2603.13788, 2026.
-
arXiv preprint arXiv:2603.08383, 2026.
-
arXiv preprint arXiv:2605.27582, 2026.
2025
-
arXiv preprint arXiv:2510.13149, 2025.
-
International Conference on Learning Representations (ICLR), 2025.
2024
-
Conference on Neural Information Processing Systems (NeurIPS), 2024.
-
International Conference on Autonomous Agents and Multiagent Systems (AAMAS), 2024.
2023
-
International Conference on Autonomous Agents and Multiagent Systems (AAMAS), 2023.
Honors and Awards
- 2026.07 Yuxiu Young Scholar (毓秀青年学者), Nanjing University
- 2026.06 Best Paper Award, ICRA 2026 Workshop on Generative Digital Twins for Real2Sim and Sim2Real Transfer (V-Dreamer)
- 2026.06 Best Presentation Finalist, ICRA 2026 Workshop on Robots Meet Prior Maps (INHerit-SG)
- 2023.07 China Scholarship Council (CSC) Scholarship
- 2022.10 Nanjing University Graduate Talent Scholarship
- 2020.06 Outstanding Graduate Student of Soochow University
- 2019.10 Soochow University Graduate Academic Scholarship, First Prize
- 2018.10 Soochow University Graduate Academic Scholarship, Second Prize
Services
- Conference Reviewer: NeurIPS, ICLR, ICRA, IROS, CoRL, AAAI, CVPR
- Journal Reviewer: IEEE TNNLS, RA-L, TASE
Internships
- 2019.06 - 2019.10: Research Intern at NetEase Fuxi Lab, Hangzhou, China.
Powered by Jekyll and Minimal Light theme.